
Products / 3-Axis Force Platforms & Dynamometers / MXL-PLT-GAIT
Requested configuration / drawing review
MXL-PLT-GAIT
Force platform / dynamometer configuration
6-Component Force Platform [Fx…Mz / COP]. Start a configuration review around AMTI BMS400600 architecture comparison.
Configure MXL-PLT-GAIT RFQ ↗+Fx / X+Fy / Y+Fz / Z
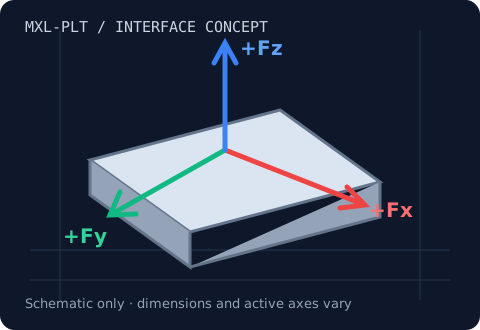
Review the requested measurement envelope.
This model page is an engineering request sheet. The identifier and target envelope do not establish a released stock item, approved dimensional drawing or verified replacement.
| Review item | Requested MXL configuration |
|---|---|
| Measured components | 6-Component Force Platform [Fx…Mz / COP] |
| Force capacity target | Per application and subject loading |
| Moment capacity target | Force/moment and COP review |
| MXL dimensions and mounting | Drawing review required |
| Electrical interface | Per-axis bridge input/output resistance, excitation, sensitivity and pinout to confirm |
| Performance evidence | Crosstalk, combined loads, uncertainty, temperature behavior and safe/ultimate limits to confirm |
Resolve the details specific to this configuration.
- Force, moment and center of pressure require assembled-platform calibration and known sensing coordinates.
- Define plate surface, coordinate origin, acquisition synchronization and the research protocol.
- No clinical approval or measured COP accuracy is established by a planning identifier.
Define acceptance before approving the quotation.
- Confirm independent component ranges and the worst simultaneous load event.
- Approve both mounting faces, clearances, fastener engagement and the cable route.
- Match excitation, bridge loading, nominal sensitivity and controller input range.
- Agree on calibration evidence, useful bandwidth, timing and environmental requirements.
Send the actual original-model revision for replacement work. CAD and lead time are confirmed against the approved configuration rather than inferred from the reference name.
Compare other MXL-PLT configurations.
| Configuration / measured components | Requested force capacity | Requested moment capacity | MXL dimensions / interface | Calibration / cross-axis limits | Configure |
|---|---|---|---|---|---|
| MXL-DYN10 3-Axis Heavy Force Platform | up to ±10 kN requested | Fixture-dependent moment envelope | Drawing review required | Calibration, crosstalk, safe/ultimate overload and combined-load limits to confirm | Configure RFQ → |
| MXL-DYN30 3-Axis Heavy Force Platform | up to ±30 kN requested | Fixture-dependent moment envelope | Drawing review required | Calibration, crosstalk, safe/ultimate overload and combined-load limits to confirm | Configure RFQ → |
| MXL-PLT-GAIT 6-Component Force Platform [Fx…Mz / COP] | Per application and subject loading | Force/moment and COP review | Drawing review required | Calibration, crosstalk, safe/ultimate overload and combined-load limits to confirm | Configure RFQ → |
| MXL-PLT-LG 3-Axis Heavy Force Platform | 50–500 kN requested | Landing-gear impact envelope | Drawing review required | Calibration, crosstalk, safe/ultimate overload and combined-load limits to confirm | Configure RFQ → |
| MXL-6D-MC3A 6-Axis Force & Torque [Fx…Mz] | Application range by request | Six-component block review | Drawing review required | Calibration, crosstalk, safe/ultimate overload and combined-load limits to confirm | Configure RFQ → |