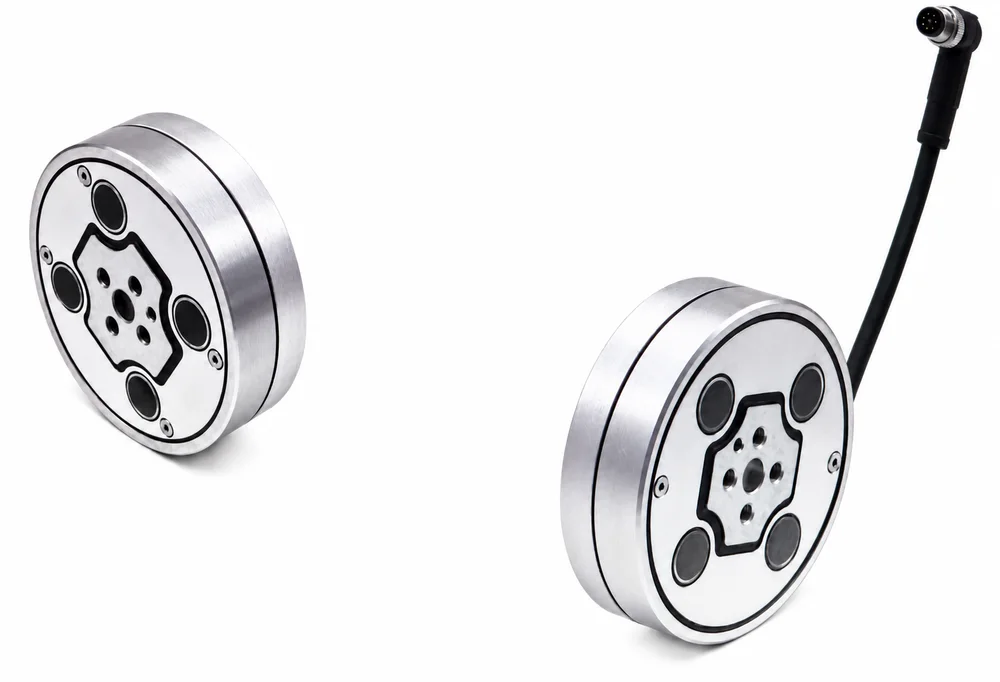
Define the measurement before choosing a package.
Grinding and polishing need a stable normal contact force while the tool moves over the workpiece. A triaxial configuration separates normal force from in-plane reactions when the contact frame is known; a wrist force/torque sensor also captures moments caused by the tool offset. Neither axis count alone establishes a stable control loop.
For assembly and insertion, define contact-force thresholds, fixture stiffness, tool mass and the stopping event. The sensor reference frame, tool-center-point transform, filtering and controller update delay need to be reviewed together. A maximum sample rate is not the same as the closed-loop force bandwidth.
Fingertip and dexterous-hand work changes the cable and acquisition problem. Five triaxial fingertips create 15 raw sensing channels before any local conversion or aggregation. The proposed HAND-5X request covers sensor envelope, strain relief, local digitization and a supported wrist-board interface; compatibility with a particular hand is reviewed from its drawings.